To contents
MyRobotica Courses

Learning to build autonomous robots

Free courses for students and teachers. Take them in the app with the simulator and knowledge checks, or read them here.

Available · draft 0.2.0

Robot courier

We assemble a wheeled robot and teach it to drive along a line, find objects and deliver them.
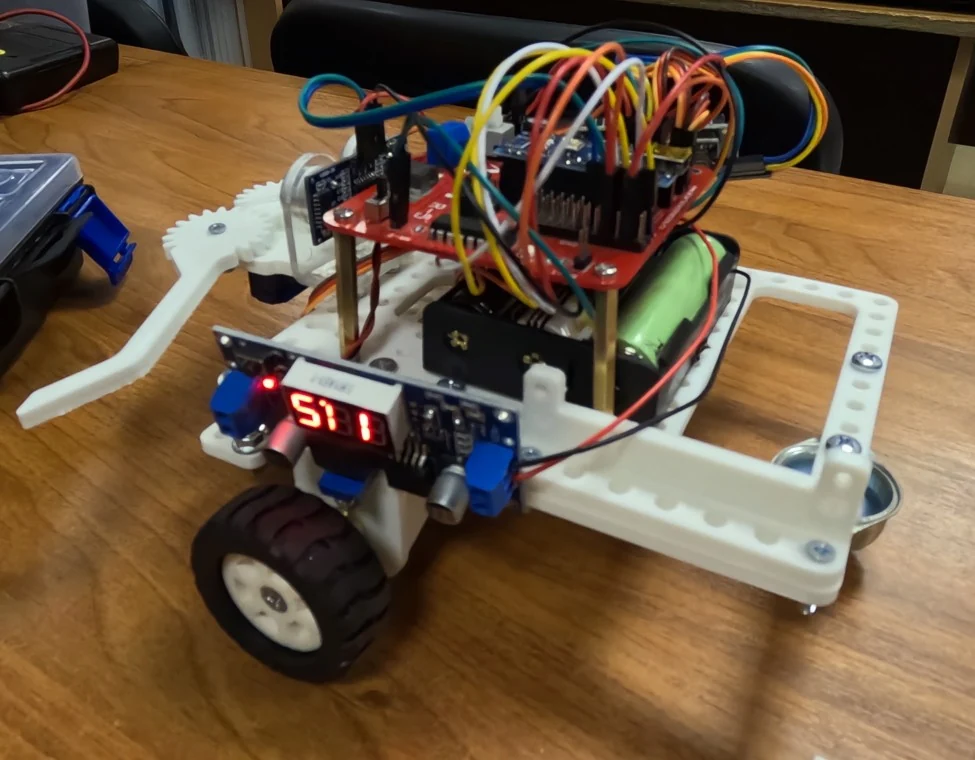
The course robot on the line
PDF

Student book in PDF

The whole course in one printable file: cover, contents, every lesson and the logbook. Choose the level of the final task.

For teachers

For the teacher

The course guide is open here. Lesson guides with solutions and answer keys are in the app for teachers.

Code

Arduino sketches

Student programs for every lesson.

L11_Diagnostics.ino1-1-assemblyL11_Diagnostics_Empty.ino1-1-assemblyL11_Diagnostics_Gaps.ino1-1-assemblyL11_Empty.ino1-1-assemblyL21_Both_Motors.ino2-1-motorsL21_Both_Motors_Gaps.ino2-1-motorsL21_Left_Motor.ino2-1-motorsL21_Left_Motor_Gaps.ino2-1-motorsL21_Moves.ino2-1-motorsL21_Moves_Gaps.ino2-1-motorsL22_Turn_Test.ino2-2-turnsL22_Turn_Test_Gaps.ino2-2-turnsL22_Turns.ino2-2-turnsL22_Turns_Gaps.ino2-2-turnsL31_First_Line.ino3-1-line-sensorsL31_First_Line_Gaps.ino3-1-line-sensorsL31_First_Line_Skeleton.ino3-1-line-sensorsL31_Line_Detect.ino3-1-line-sensorsL31_Line_Detect_Gaps.ino3-1-line-sensorsL31_OnLine_Test.ino3-1-line-sensorsL31_Read_Sensors.ino3-1-line-sensorsL31_Read_Sensors_Gaps.ino3-1-line-sensorsL32_Error.ino3-2-p-controllerL32_Error_Gaps.ino3-2-p-controllerL32_Level_Test.ino3-2-p-controllerL32_P_Line.ino3-2-p-controllerL32_P_Line_Gaps.ino3-2-p-controllerL32_P_Line_Skeleton.ino3-2-p-controllerL41_Count.ino4-1-crossingsL41_Count_Gaps.ino4-1-crossingsL41_Crossing_Stop.ino4-1-crossingsL41_Crossing_Stop_Gaps.ino4-1-crossingsL42_Route.ino4-2-routeL42_Route_Gaps.ino4-2-routeL42_Turn_At_Crossing.ino4-2-routeL42_Turn_At_Crossing_Gaps.ino4-2-routeL51_Distance.ino5-1-ultrasonicL51_Distance_Gaps.ino5-1-ultrasonicL51_Stop_At_Can.ino5-1-ultrasonicL51_Stop_At_Can_Gaps.ino5-1-ultrasonicL52_Pick_Place.ino5-2-gripperL52_Pick_Place_Gaps.ino5-2-gripperL52_Servo_Test.ino5-2-gripperL52_Servo_Test_Gaps.ino5-2-gripperL61_Courier.ino6-1-final-planL61_Courier_Plan.ino6-1-final-planLF1_Count.inof-1-encodersLF1_Count_Gaps.inof-1-encodersLF1_Distance.inof-1-encodersLF1_Distance_Gaps.inof-1-encodersLF1_Ticks_Test.inof-1-encodersLF2_Compare.inof-2-controllersLF2_Compare_Gaps.inof-2-controllersLF2_Compare_Skeleton.inof-2-controllersLF2_Controller_Test.inof-2-controllers
Coming soon

Upcoming courses

Planned

Machine vision

A camera, object and marking recognition. Tentatively on ESP32-S3.

Planned

AI control

Learning behaviour and a neural network on the robot.

For partners

Courses on partner robots

Courses from robot manufacturers in the same environment.